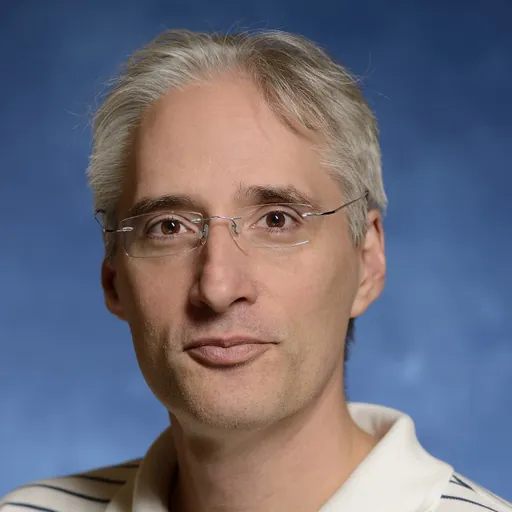
Gregory S. Chirikjian
American roboticist (born 1966)
About Gregory S. Chirikjian
Born 1966. Gregory S. Chirikjian is an American applied mathematician, roboticist and university teacher, known for Kinematics.
Gregory Scott Chirikjian (born 1966) is an American roboticist and applied mathematician, primarily working in the field of kinematics, motion planning, computer vision, group theory applications in engineering, and the mechanics of macromolecules. A longtime professor of Mechanical Engineering at Johns Hopkins University, he recently served as the chair and professor at the Department of Mechanical Engineering at the University of Delaware, and is now a professor in the Robotics Department at Mohamed bin Zayed University of Artificial Intelligence in Abu Dhabi. He is known for his theoretical contributions to the kinematics of hyper-redundant (snake-like and continuum) robots and stochastic methods on Lie groups.
Academic life Chirikjian received a bachelor's degree from Johns Hopkins University (JHU), Baltimore, MD, USA, in 1988, and the Ph.D. degree from the California Institute of Technology, Pasadena, CA, USA, in 1992. From 2019 to 2023, he was the Chair of the Department of Mechanical Engineering, National University of Singapore. Unitl recently he was the chair of the Department of Mechanical Engineering at University of Delaware. and is now a professor in the Robotics Department at Mohamed bin Zayed University of Artificial Intelligence in Abu Dhabi.
Selected Research Accomplishments
Chirikjian's PhD work established the concept of `hyper-redundant' (snakelike and continuum) robots and developed framed `backbone curve' models to represent such robots both in terms of their geometrical and inertial properties. These models essentially form the basis for all studies in continuum robots today.
In the 1990s he pioneered `metamorphic' (modular self-reconfigurable) robotic systems, in an attempt to make liquid-like robots that can morph into various shapes, as in a well-known SciFy movie from 1991 that inspired his work on this topic.
In the 2000s Chirikjian worked on robotic self-replication and self-repair. He also applied earlier work on hyper-redundant robotic manipulators to model DNA statistical mechanics, as well as developing computer models of how protein molecules change shape as part of their function.
In the 2010s, he initiated the use of Lie-theoretic methods (e.g., the closed-form `banana distribution') to model uncertainty propagation in robotics, which has become the cornerstone of invariant Kalman filtering. He observed that essentially the same mathematical model that describes DNA statistical mechanics can be used to model the uncertainty in a vehicle's position and orientation, by replacing the framed DNA backbone curve with the time-parameterized trajectory traversed by the vehicle. Starting at this time he also began work on closed-form mathematical expressions for the boundaries of Minkowski sums of ellipsoids, and then generalized that result to Minkowski sums of any bodies with smooth positively curved boundaries.
In the 2020s, he has moved into the area of physical AI, affordance-based reasoning, and `Robot Imagination' while continuing to make contributions to earlier topics. During the COVID lockdown in Singapore, he and his team made rapid progress on this, as well as on completing the Minkowski sum work. Recently, his research group has integrated this into robot motion planning, collision avoidance, and computer vision algorithms that support the concept of `Robot Imagination'.
Awards and honors Chirikjian was named NSF's Young Investigator in 1993, Presidential Faculty Fellow in 1994, In 2019, he received the American Society of Mechanical Engineers' Machine Design Award.
Don’t just read it —
keep it.
Full-length biographies made to live with: read them, listen on the way to work, watch them tonight.
- E-book
- Audio
- Video
Instant download · yours to keep · every purchase keeps this site free
Important facts
Related people
Same field, nearest in time
Contemporaries
People whose lives overlapped Gregory S. Chirikjian's

Frequently asked questions
Who is Gregory S. Chirikjian?
American roboticist (born 1966)
When was Gregory S. Chirikjian born?
Gregory S. Chirikjian was born in 1966.
What is Gregory S. Chirikjian's occupation?
Gregory S. Chirikjian is an applied mathematician, roboticist and university teacher.
What is Gregory S. Chirikjian known for?
Gregory S. Chirikjian is known for Kinematics.
What nationality is Gregory S. Chirikjian?
Gregory S. Chirikjian is American.
Sources & further reading
· Wikipedia: Gregory S. Chirikjian
· DBpedia: Gregory S. Chirikjian
Cite this page
APA: Biography.guide. (2026). Gregory S. Chirikjian. https://biography.guide/gregory-s-chirikjian/
MLA: "Gregory S. Chirikjian." Biography.guide, https://biography.guide/gregory-s-chirikjian/.
Chicago: "Gregory S. Chirikjian." Biography.guide. https://biography.guide/gregory-s-chirikjian/.
Data last updated: 2026-09-24 · Spot an error? Report a correction.
Portrait: Wikimedia Commons · author & licence
Page generated 2026-09-27 05:08 UTC